
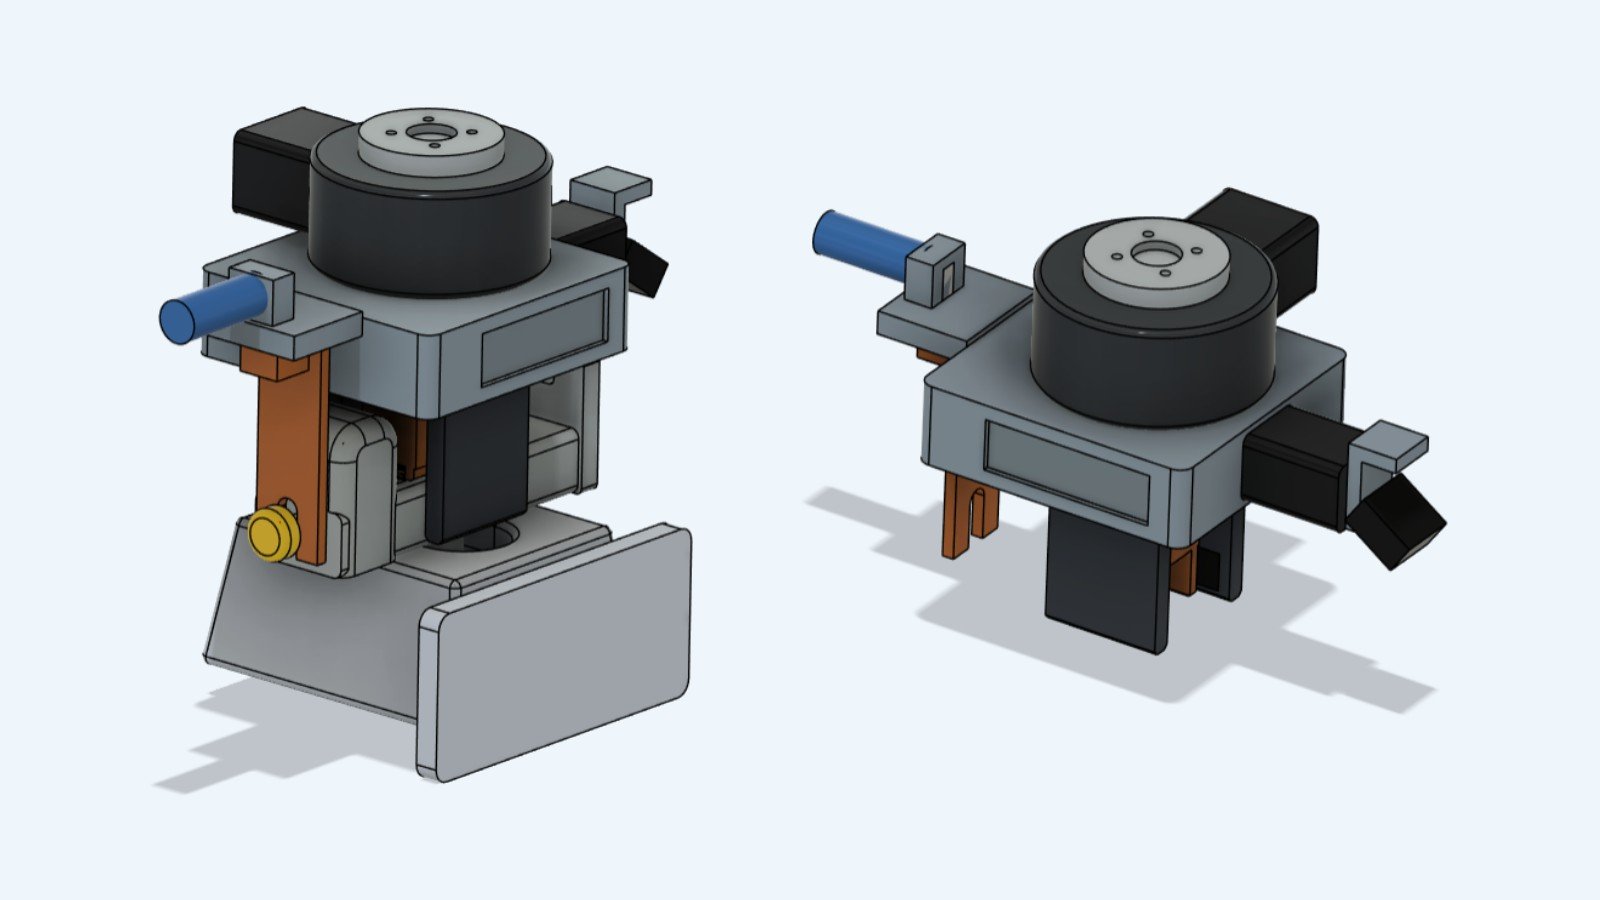
A concept study for automating coning and de-coning at container terminals: fitting and removing the twistlocks that lock stacked containers together at their corners. Today lashing crews do this by hand, right under a container hanging from the quay crane. We built a first working concept for one fitting type in 3D, then mapped out how the same tool could grow to cover the whole family of fittings.
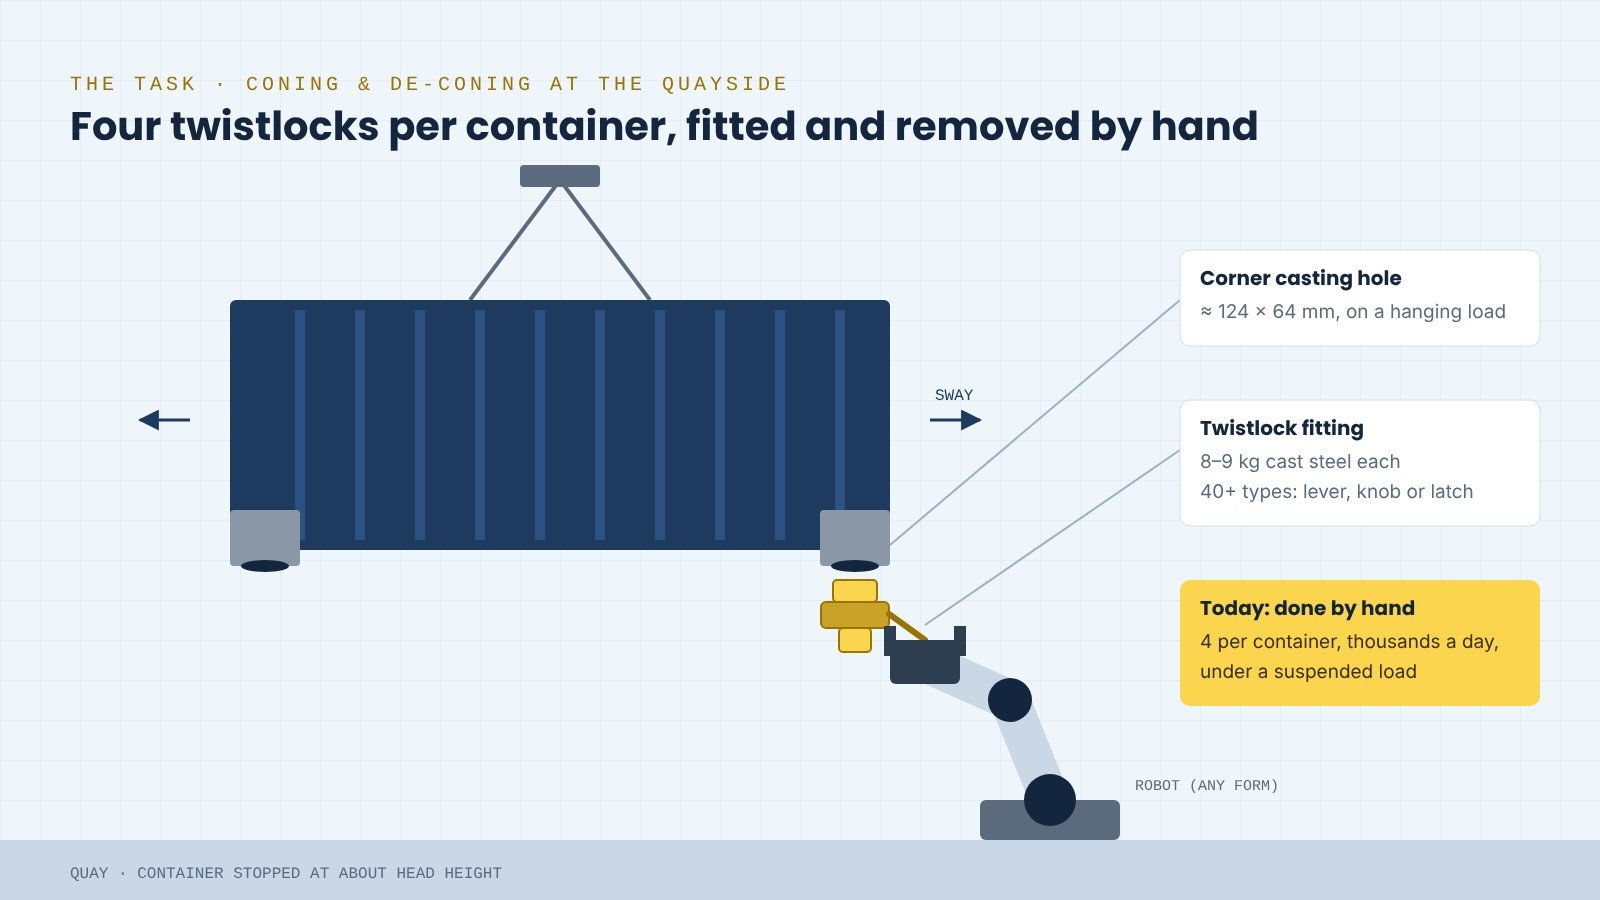
Why it is hard to automate
- Weight: each cast-steel fitting weighs about 8–9 kg, more than most dexterous robot hands can hold.
- Variety: more than 40 twistlock types are in use, each with a different lever, knob or latch. The robot has to recognise the type and work its mechanism, not just grab it.
- Precision: the fitting must go into a corner-casting hole of about 124 × 64 mm on a container that hangs from a crane and may sway, then be turned and latched.
- Form: the robot does not need to be a humanoid; any form that suits the job is fine.
- Safety: the work is heavy, repetitive and done under suspended loads, so it carries injury and fatigue risk.
First concept: one fitting, the full lock and unlock cycle
We started with one real fitting type, a spring-loaded knob-release fitting, and a mock corner-casting block with the standard 124 × 64 mm slot. The end effector grips the 8 kg fitting body, pulls the knob with a fork, twists the T-head 90° to lock it in the block and then reverses the steps to unlock it. Try the interactive model below: drag to orbit, and click any step to jump to it.