Design
Industrial Automation

Automated O-Ring & Fastener Assembly Cell (OAS-4)

A compact Yaskawa GP4 cell that feeds bolts and O-rings, fits each O-ring onto its bolt with a dual-action end effector, and conveys finished assemblies out.

Client
Timeline
Service
Design
Industry
Industrial Automation
Services provided
  • Assembly cell concept and 3D CAD
  • Dual-action insertion end effector design
  • Bowl feeder, escapement and nest integration
  • Renders and process visualisation
01 · The challenge

Problem statement

Fitting O-rings onto bolts by hand is repetitive and error-prone, and O-rings tend to tangle and nest. The cell had to singulate both parts reliably and assemble them at high speed in a small footprint.

02 · The work
Automated O-Ring & Fastener Assembly Cell (OAS-4)
Cell overview

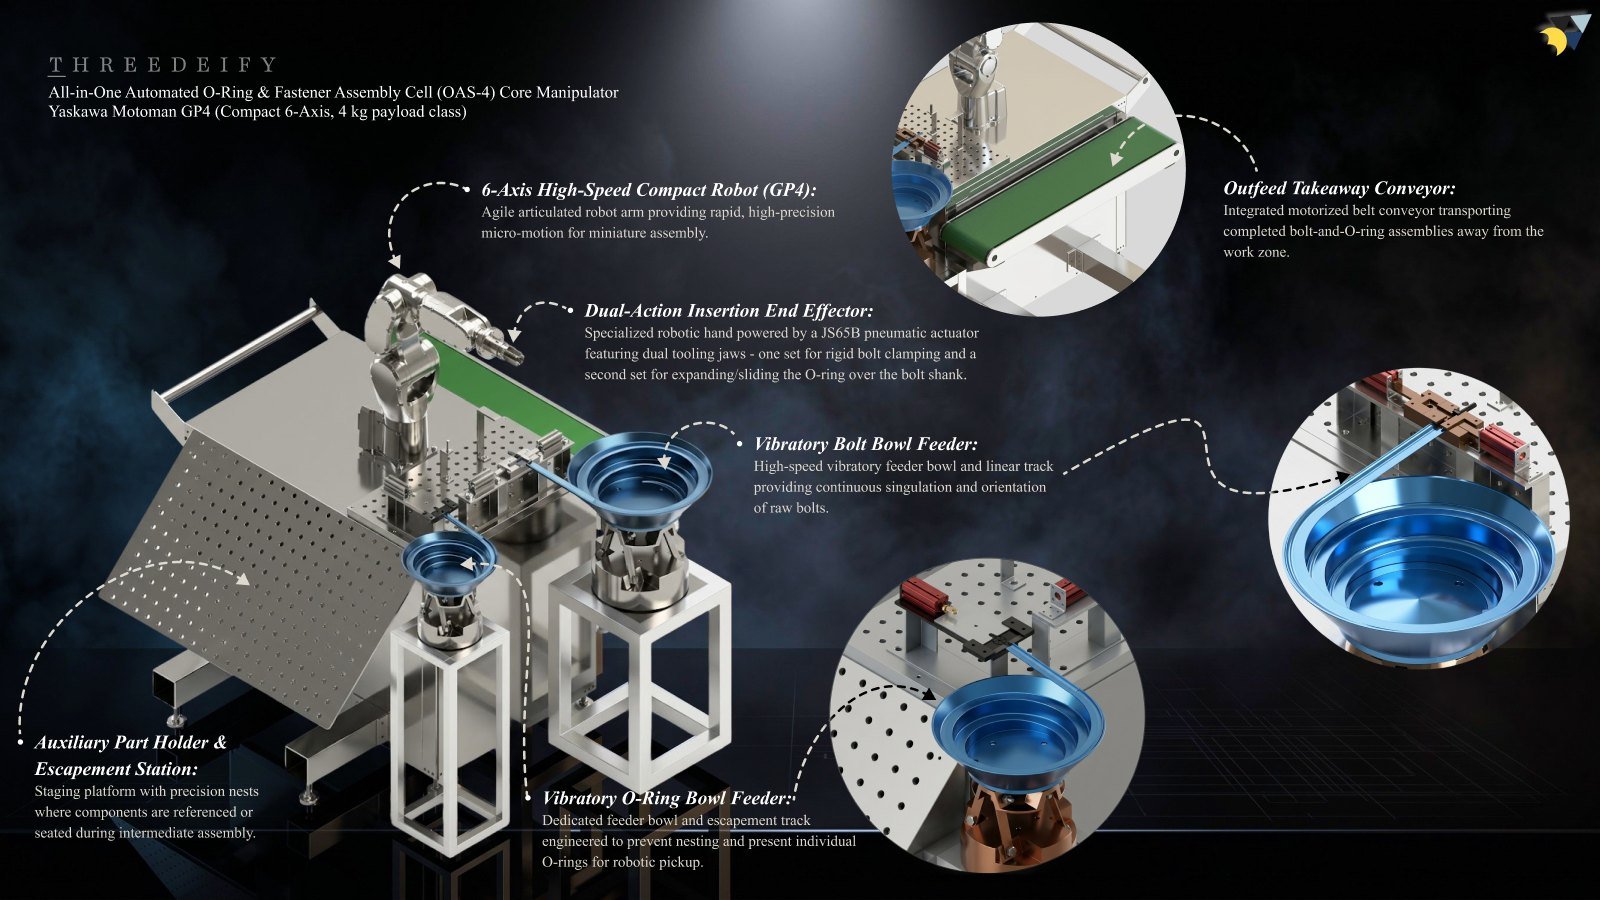
A compact Yaskawa Motoman GP4 cell that singulates bolts and O-rings from two bowl feeders, fits each O-ring onto its bolt with a dual-action end effector, and conveys finished assemblies away.

The cell
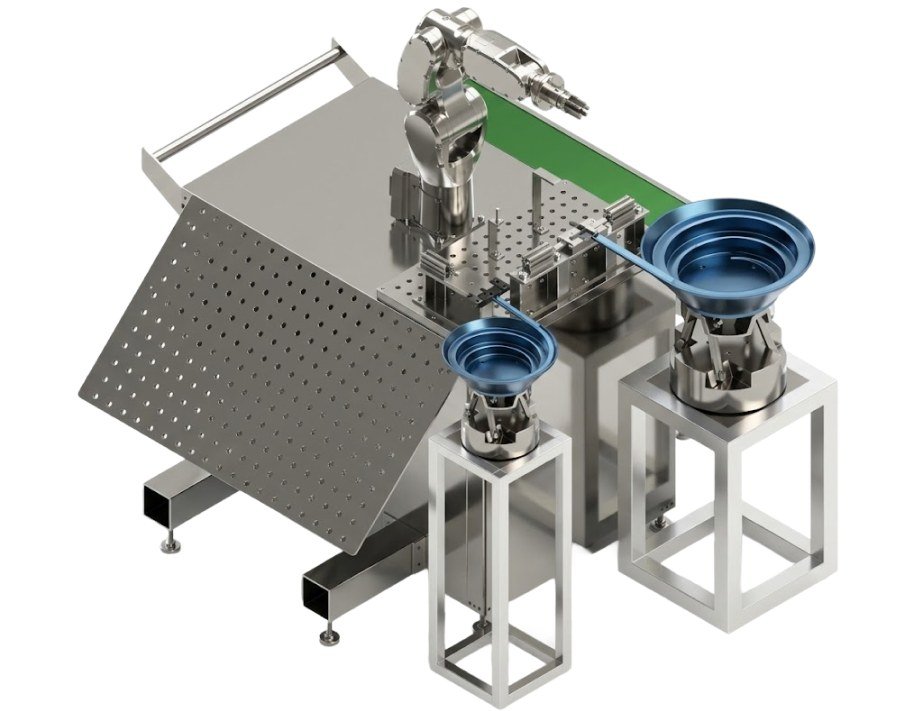
Automated O-Ring & Fastener Assembly Cell (OAS-4) 3D render

Key components

  • Vibratory bolt bowl feeder: high-speed bowl and linear track that singulate and orient raw bolts.
  • Vibratory O-ring bowl feeder: dedicated bowl and escapement track engineered to stop O-rings nesting and present them one at a time.
  • Auxiliary part holder & escapement station: staging platform with precision nests where parts are seated during intermediate assembly.
  • 6-axis high-speed compact robot (GP4): agile arm for fast, precise micro-motion in miniature assembly.
  • Dual-action insertion end effector: JS65B pneumatic actuator with two jaw sets: one clamps the bolt, the other expands and slides the O-ring over the shank into the groove.
  • Outfeed takeaway conveyor: motorised belt carrying completed bolt-and-O-ring assemblies out of the work zone.

Close-up details
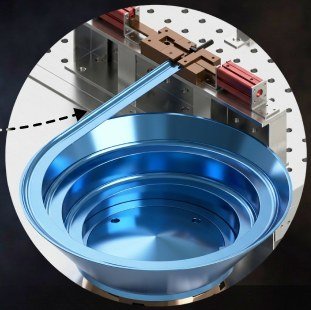
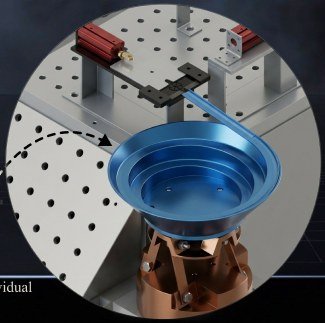
Vibratory bolt bowl feeder

Vibratory bolt bowl feeder

The bowl and linear track singulate bolts and present them in a repeatable orientation at the escapement, so the robot always picks from the same point.

Vibratory O-ring bowl feeder

A dedicated bowl and escapement prevent O-rings tangling or nesting and feed them individually to the pick position.
Vibratory O-ring bowl feeder
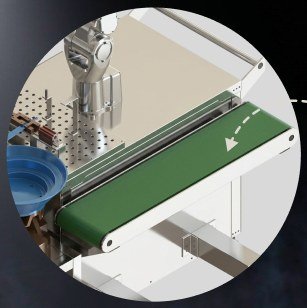
Outfeed takeaway conveyor

Outfeed takeaway conveyor

Finished assemblies are placed on a motorised belt that carries them out of the robot envelope for packing or the next process.
03 · The result

Final outcome

A cell built around a Yaskawa Motoman GP4 with two vibratory bowl feeders (bolts and O-rings), an auxiliary holder and escapement station, and an outfeed conveyor. A custom end effector powered by a JS65B pneumatic actuator clamps the bolt with one jaw set while a second set expands and slides the O-ring into the seal groove.

More work

Other projects

Design
Automotive

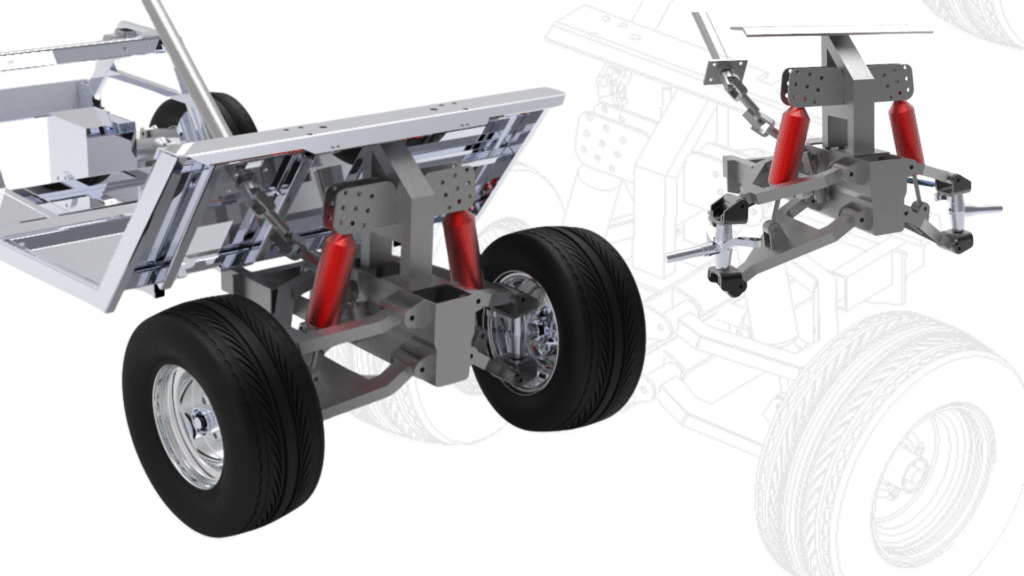
We designed a modern double wishbone front suspension and semi-trailing arm rear suspension for Auto Speed’s golf carts, replacing the old leaf springs to deliver superior ride quality and handling.

View case study →
Design
Furniture

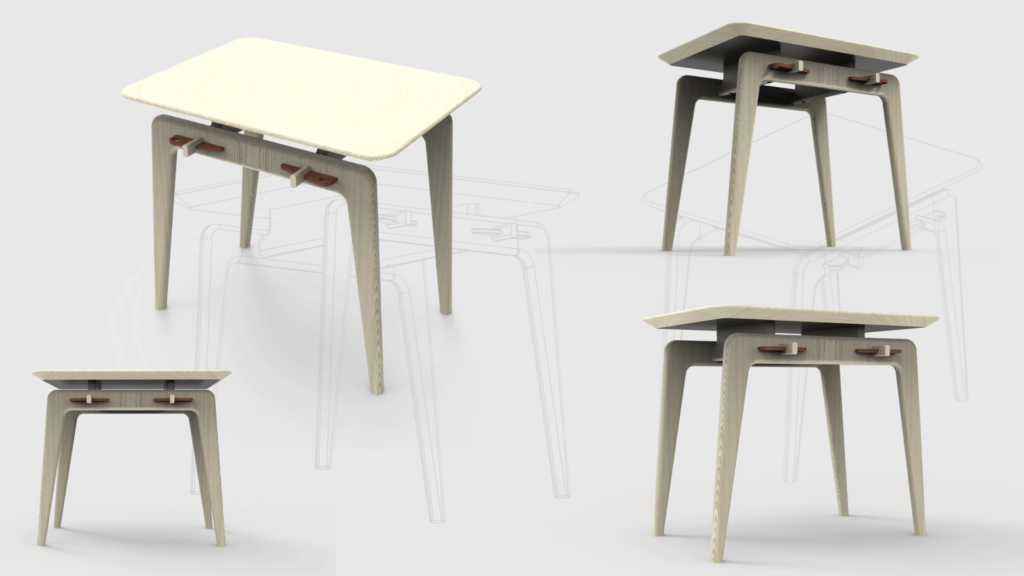
Designed for SnapNest, this compact wooden tusk coffee table is modular, easy to assemble, and comes with clear assembly instructions for convenient setup.

View case study →
Design
Medical

Concept study: a reusable, spring-actuated core biopsy instrument that fires a notched stylet and a cutting cannula 3.5 ms apart to take a clean 20 mm core in under 30 milliseconds.

View case study →
Like what you see?

Let’s build your product next.

Book a free consultation and get a clear plan for your idea within one business day.