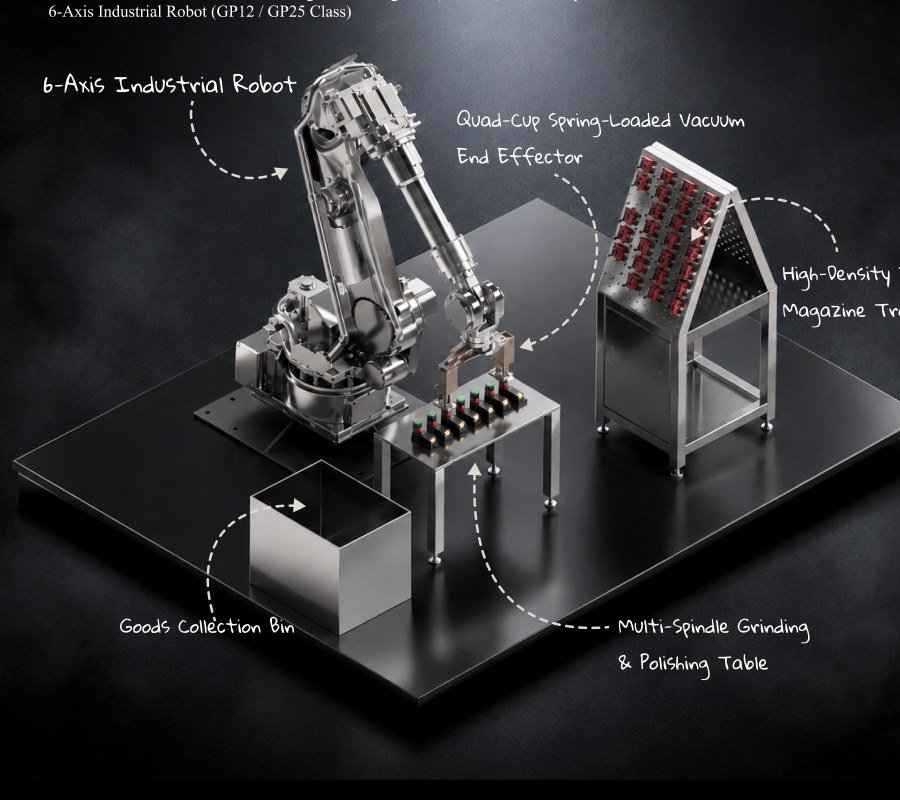
A robotic grinding cell for GP12 / GP25 class robots that picks two parts at once with a quad-cup vacuum end effector, grinds and deburrs them across a multi-spindle table, and drops them into a collection bin.
The cell
Key components
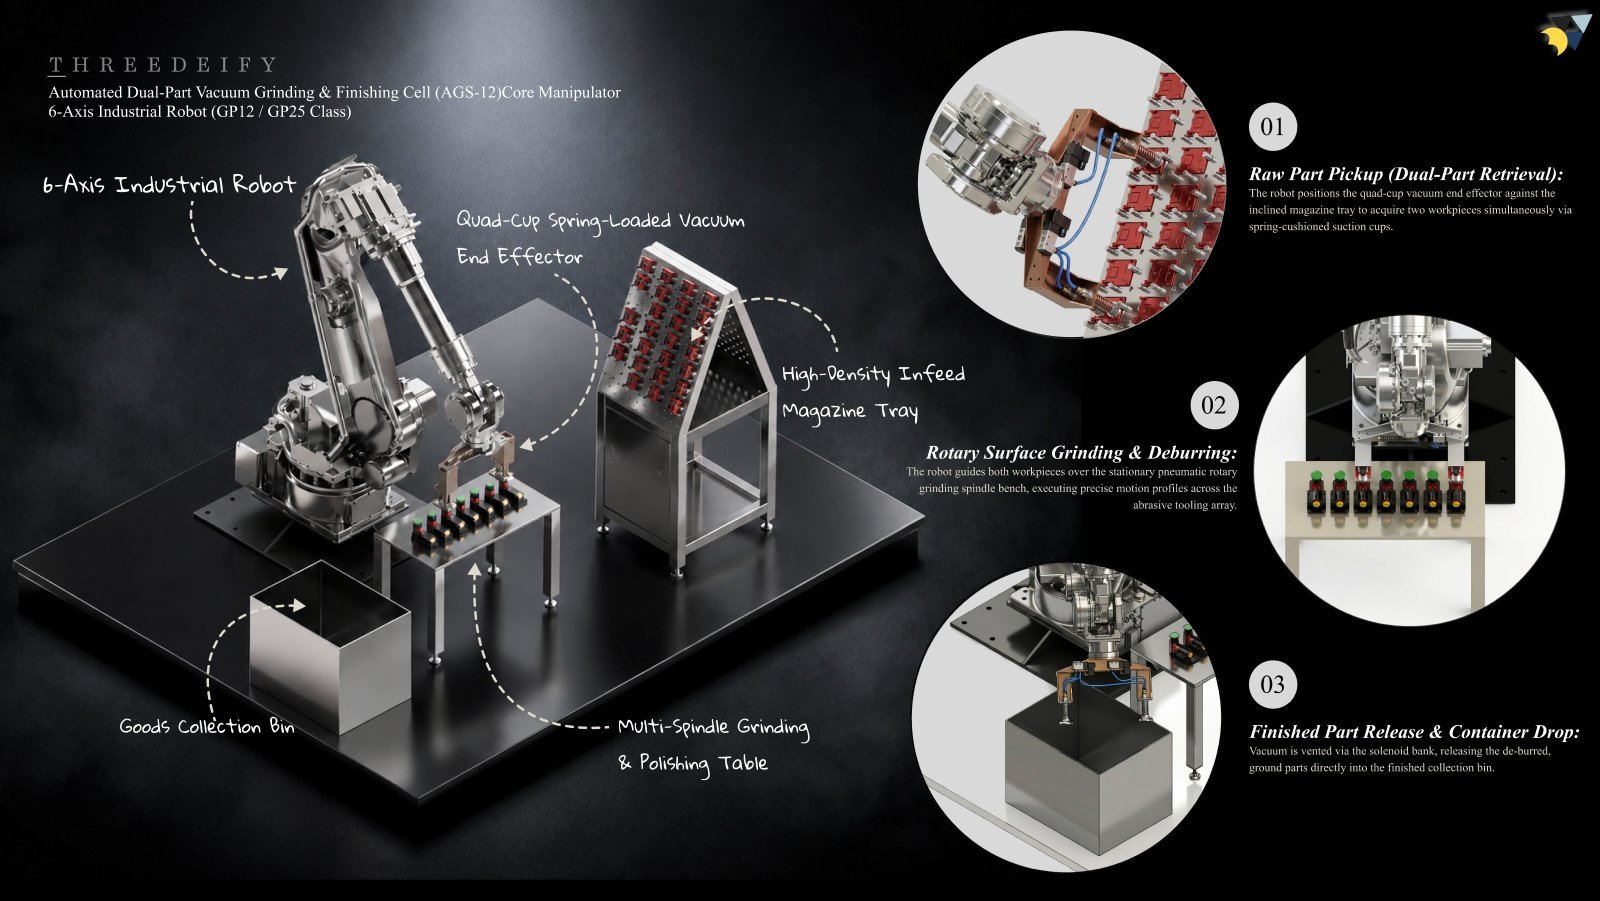
- 6-axis industrial robot: GP12 / GP25 class manipulator running the full load-grind-unload cycle.
- Quad-cup spring-loaded vacuum end effector: four sprung suction cups that pick two parts at once without marking them.
- High-density infeed magazine tray: inclined A-frame magazine holding a large batch of raw parts.
- Multi-spindle grinding & polishing table: row of pneumatic rotary spindles for surface grinding and deburring.
- Goods collection bin: finished parts are dropped straight in, with no extra handling.
Close-up details

01 · Raw part pickup (dual-part retrieval)
The robot positions the quad-cup vacuum end effector against the inclined magazine tray and picks two parts at once. The spring-cushioned cups absorb small position errors.
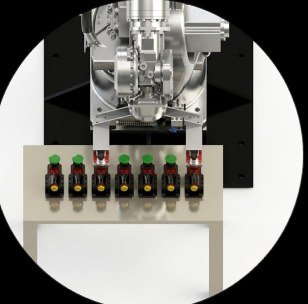
02 · Rotary surface grinding & deburring
The robot guides both parts across the stationary pneumatic spindle bench, running precise motion profiles across the abrasive tooling array.
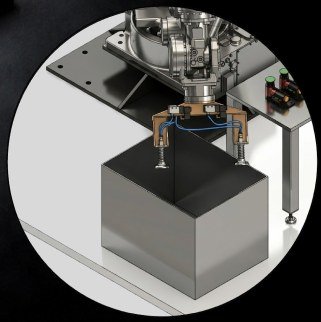
03 · Finished part release & container drop
Vacuum is vented through the solenoid bank, releasing the ground and deburred parts directly into the collection bin.