Design
Industrial Automation

Robotic Machining & Finishing Cell (FHS-12)

An all-in-one robotic cell where a Yaskawa GP12 swaps between specialised end effectors to load, grind, deburr and unload parts automatically.

Client
Timeline
Service
Design
Industry
Industrial Automation
Services provided
  • Robotic cell layout and 3D CAD
  • End effector and quick-change (FHS) design
  • Fixture, infeed table and conveyor design
  • Photoreal renders and cell visualisation
01 · The challenge

Problem statement

Grinding, deburring and cutting small machined parts by hand is slow and inconsistent. The goal was a compact cell where one robot handles every step, from raw stock to finished part, without manual tool changes.

02 · The work
Robotic Machining & Finishing Cell (FHS-12)
Cell overview

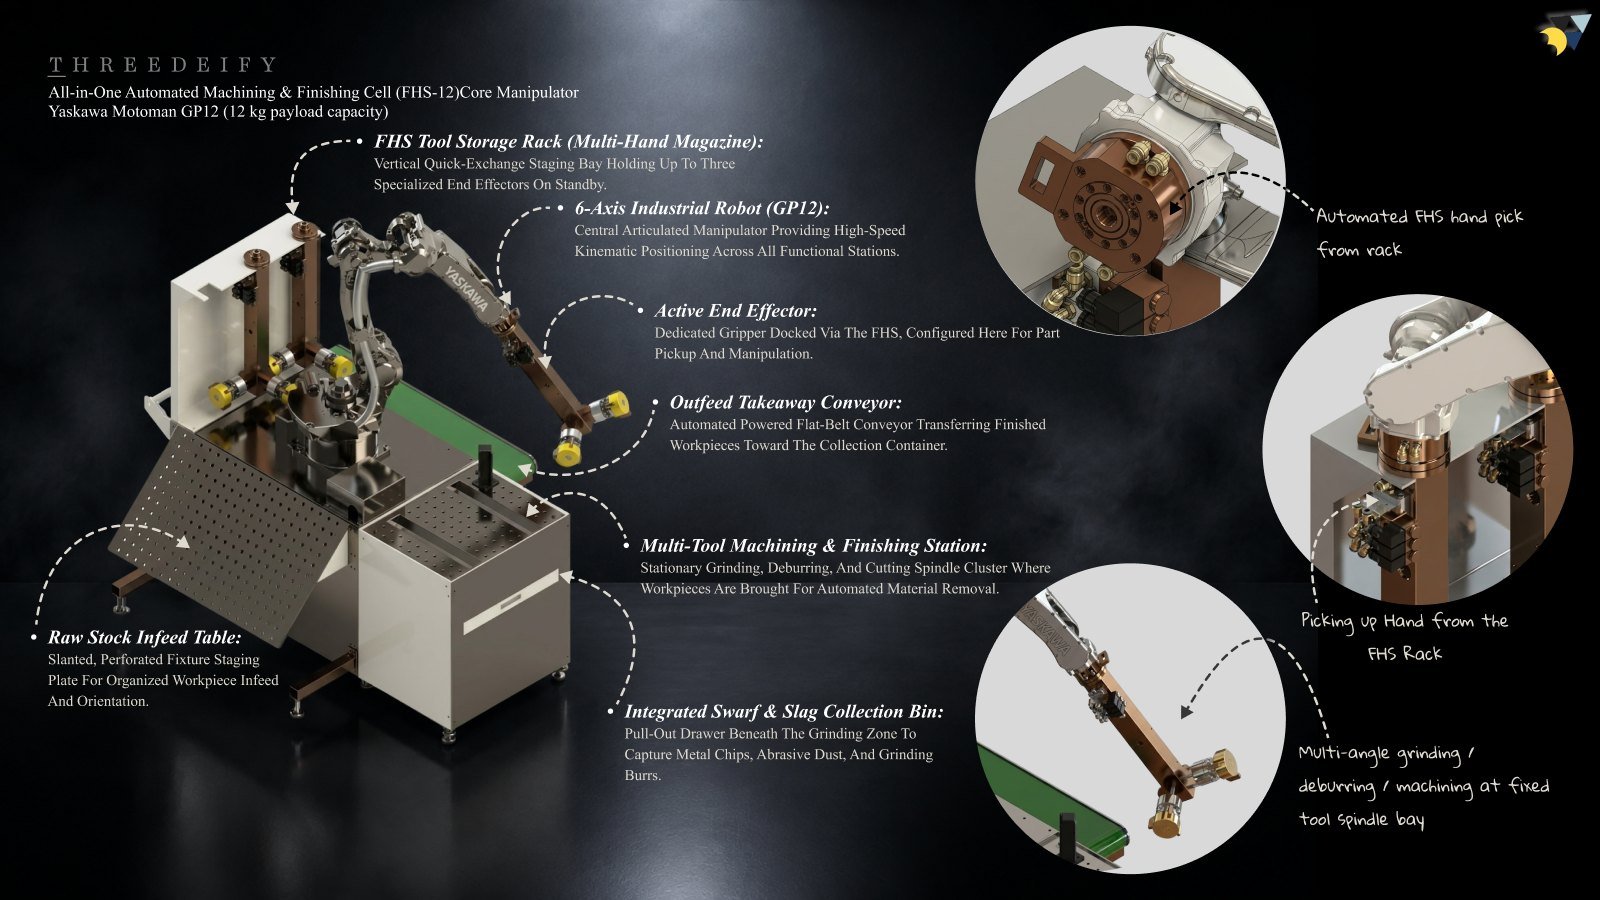
An all-in-one robotic cell in which a single Yaskawa Motoman GP12 (12 kg payload) loads, machines, finishes and unloads parts, changing its own hands from a tool rack between operations.

The cell
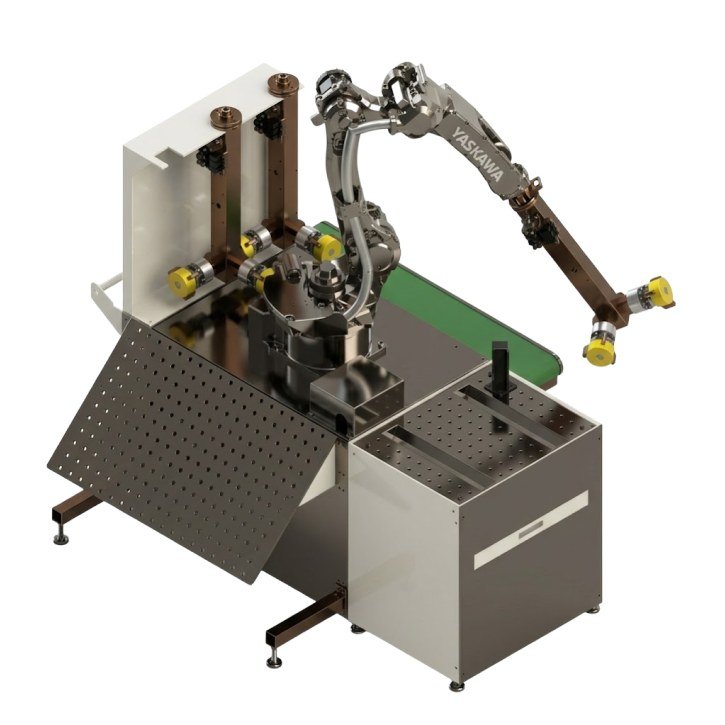
Robotic Machining & Finishing Cell (FHS-12) 3D render

Key components

  • FHS tool storage rack (multi-hand magazine): vertical quick-exchange staging bay holding up to three specialised end effectors on standby.
  • 6-axis industrial robot (GP12): central articulated manipulator providing high-speed positioning across all stations.
  • Active end effector: dedicated gripper docked via the FHS, configured for part pickup and manipulation.
  • Multi-tool machining & finishing station: stationary grinding, deburring and cutting spindle cluster where parts are brought for material removal.
  • Integrated swarf & slag collection bin: pull-out drawer under the grinding zone for chips, abrasive dust and burrs.
  • Raw stock infeed table: slanted, perforated staging plate for organised infeed and part orientation.
  • Outfeed takeaway conveyor: powered flat-belt conveyor moving finished parts to the collection container.

Close-up details
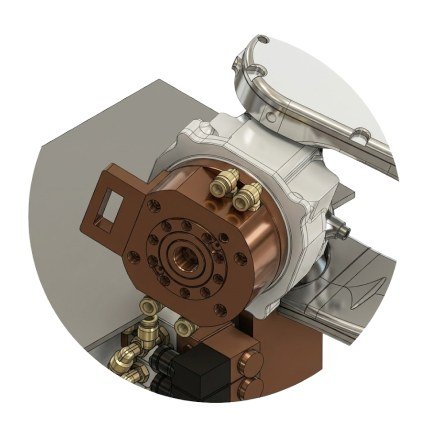
Automated FHS hand pick from the rack

Automated FHS hand pick from the rack

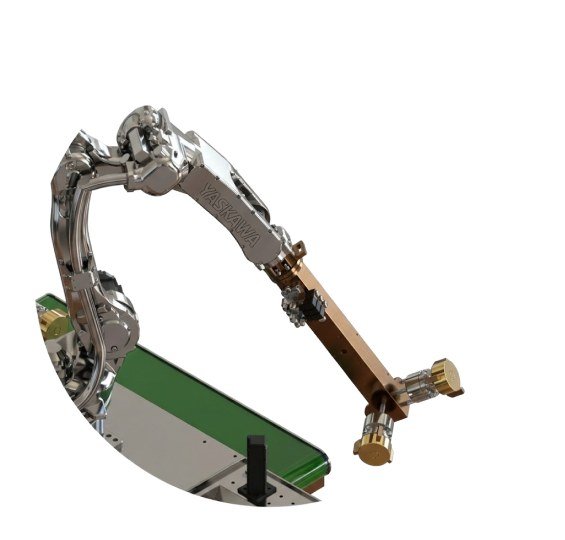
The robot flange couples to the quick-change (FHS) interface with zero-point pneumatic locking, so the GP12 picks up the right hand for each operation without an operator.

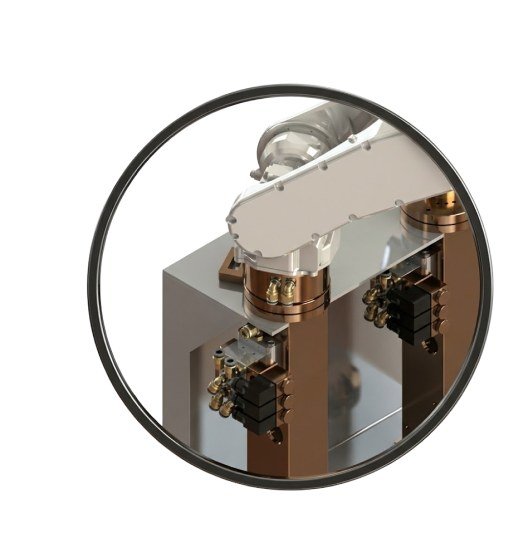
Picking up a hand from the FHS rack

Each docked hand has its own valve block and air connections, so it is ready the moment the robot docks. The rack keeps up to three tools on standby inside the cell footprint.
Picking up a hand from the FHS rack
Multi-angle grinding and deburring at the fixed spindle bay

Multi-angle grinding and deburring at the fixed spindle bay

The robot presents the part to fixed spindles at multiple angles, so the cell handles grinding, deburring and machining without moving the tools.
03 · The result

Final outcome

A complete cell design around a Yaskawa Motoman GP12 (12 kg payload): a vertical FHS rack holding up to three end effectors, a multi-tool grinding and deburring station, a slanted infeed table, a pull-out swarf bin and an outfeed conveyor. The robot picks its own hands from the rack, so one arm covers loading, finishing and unloading.

More work

Other projects

Design
Oil & Gas

A hinged, lever-locked mud bucket that clamps around a drill pipe connection and drains the fluid away, designed for Kelly Kan from 3D model to manufacturing drawings.

View case study →
Design
Industrial Automation

14 custom end effectors for Yaskawa GP4 to GP180 robots: grippers, vacuum heads, magnetic tools, compliant grinders, zero-point clamps and sensor enclosures.

View case study →
Design
Industrial Automation

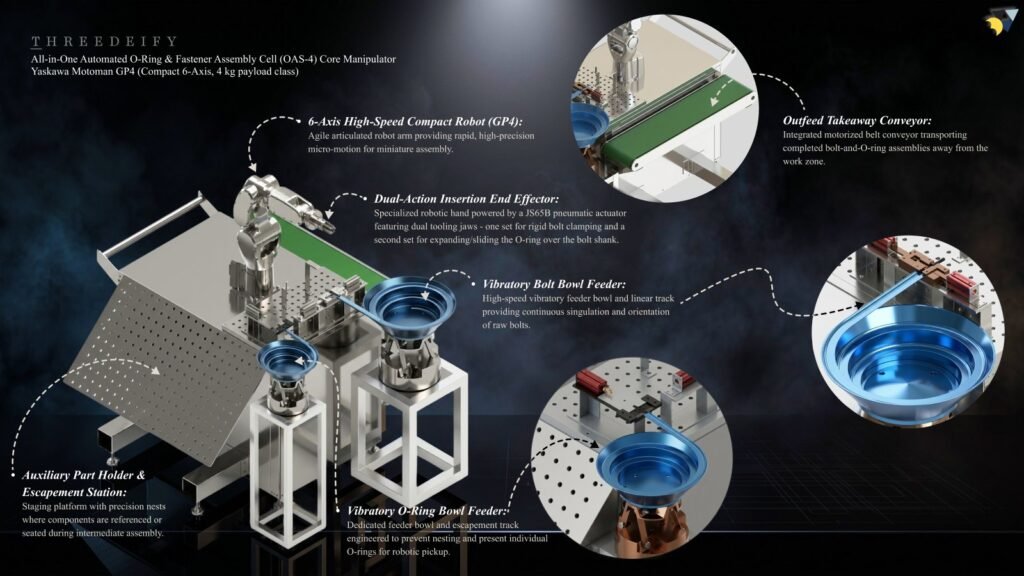
A compact Yaskawa GP4 cell that feeds bolts and O-rings, fits each O-ring onto its bolt with a dual-action end effector, and conveys finished assemblies out.

View case study →
Like what you see?

Let’s build your product next.

Book a free consultation and get a clear plan for your idea within one business day.