Design
Industrial Automation

Dual-Part Vacuum Grinding & Finishing Cell (AGS-12)

A robotic grinding cell that picks two parts at once with a quad-cup vacuum gripper, grinds and deburrs them on a multi-spindle table, and drops them into a collection bin.

Client
Timeline
Service
Design
Industry
Industrial Automation
Services provided
  • Grinding cell layout and 3D CAD
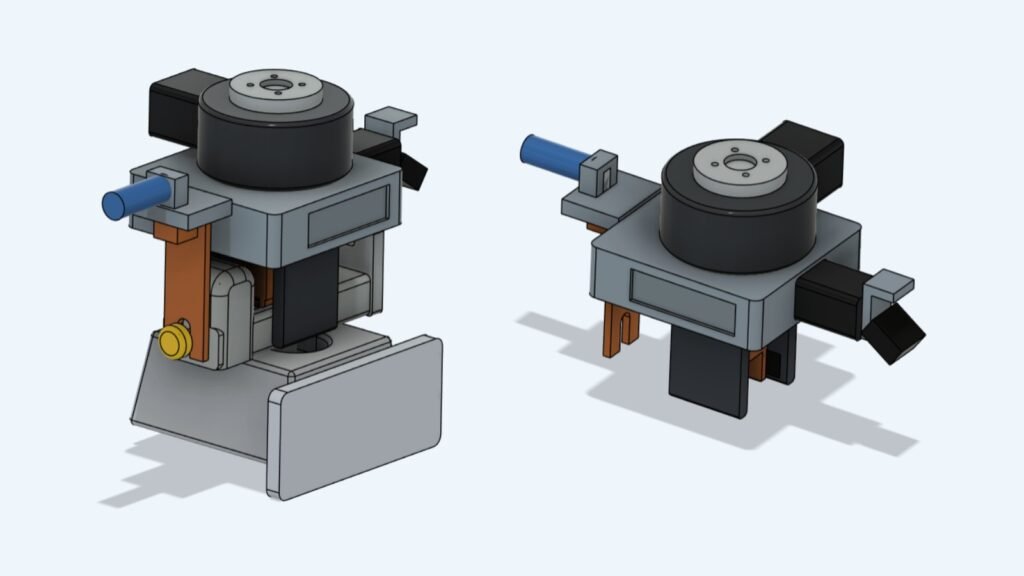
  • Quad-cup spring-loaded vacuum end effector
  • Infeed magazine and spindle table design
  • Process sequence and renders
01 · The challenge

Problem statement

Surface grinding and deburring of small flat parts needed higher throughput without marking the parts, and with a simple, repeatable load-grind-unload cycle.

02 · The work
Dual-Part Vacuum Grinding & Finishing Cell (AGS-12)
Cell overview

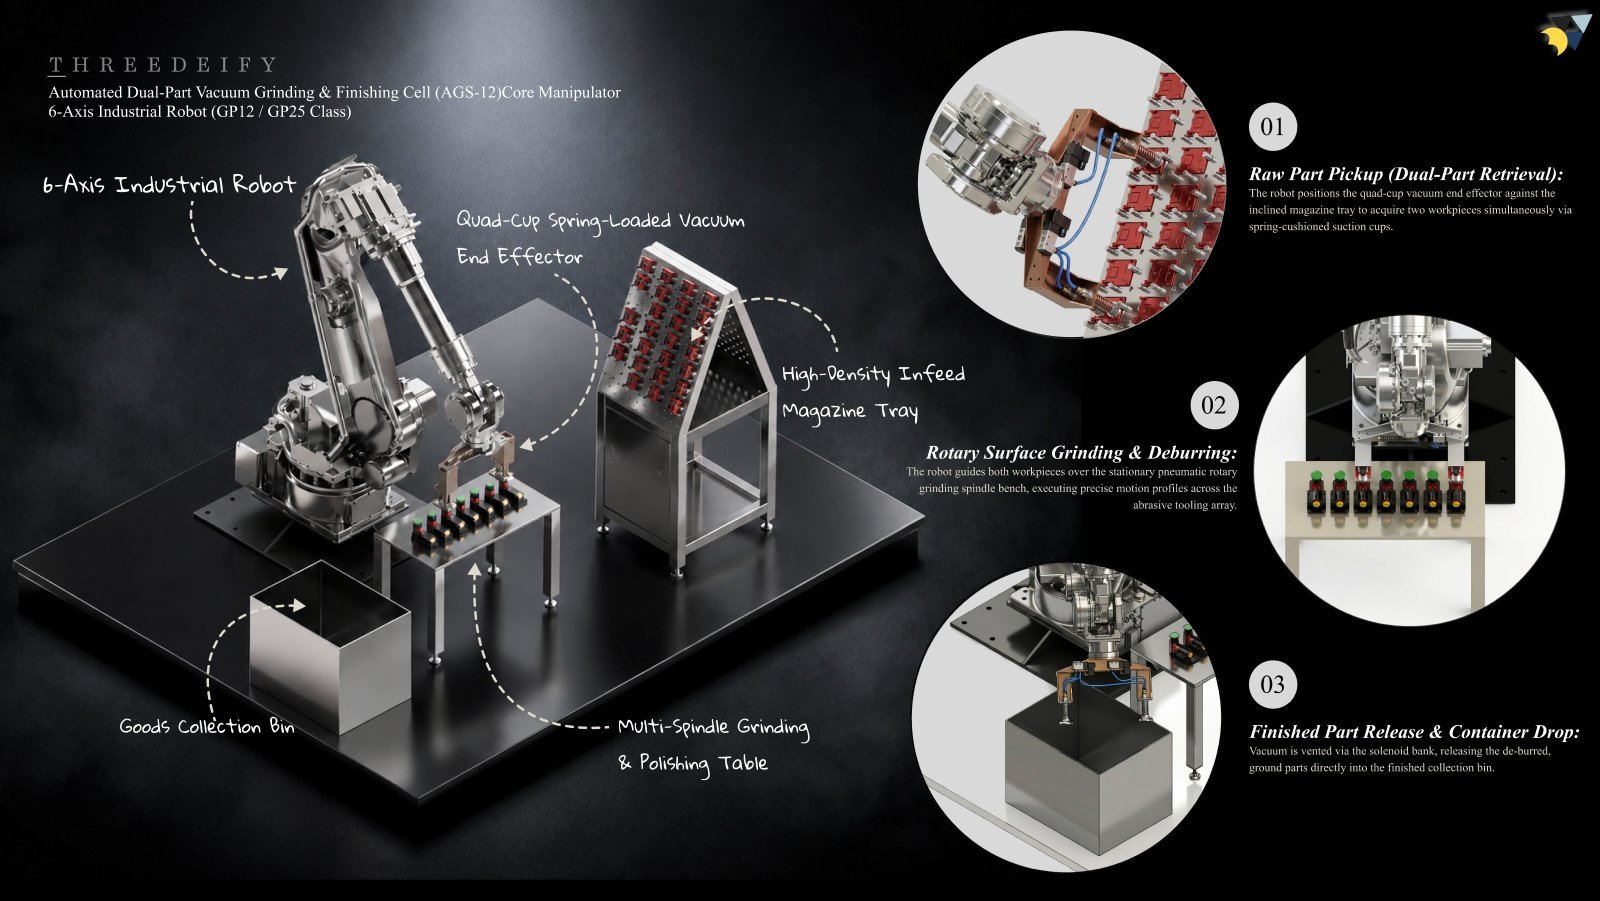
A robotic grinding cell for GP12 / GP25 class robots that picks two parts at once with a quad-cup vacuum end effector, grinds and deburrs them across a multi-spindle table, and drops them into a collection bin.

The cell
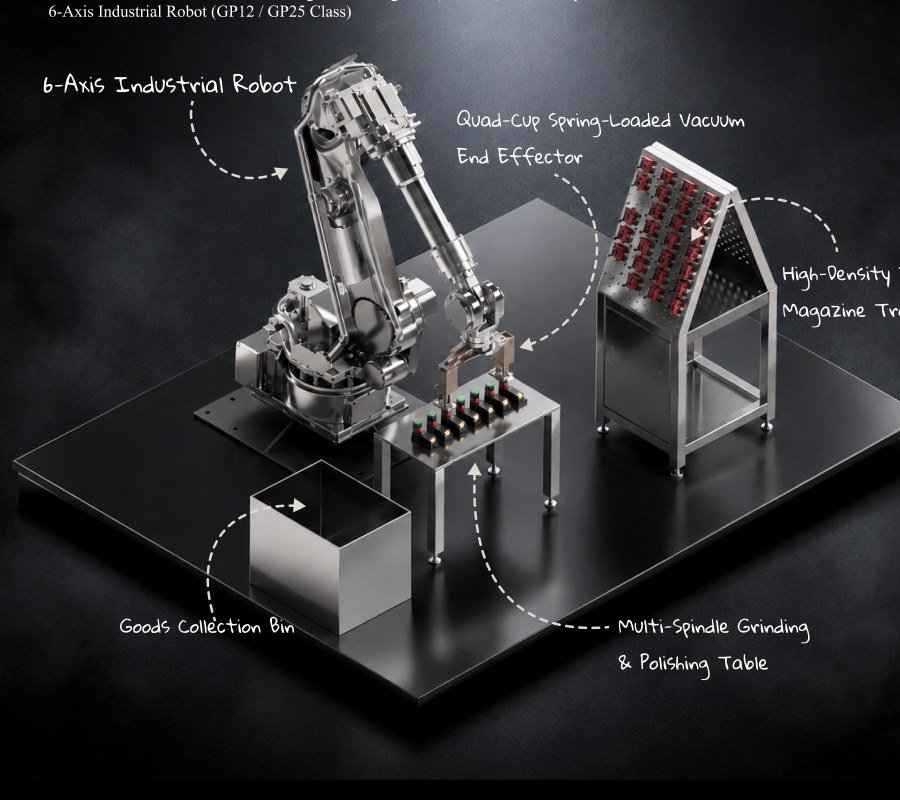
Dual-Part Vacuum Grinding & Finishing Cell (AGS-12) 3D render

Key components

  • 6-axis industrial robot: GP12 / GP25 class manipulator running the full load-grind-unload cycle.
  • Quad-cup spring-loaded vacuum end effector: four sprung suction cups that pick two parts at once without marking them.
  • High-density infeed magazine tray: inclined A-frame magazine holding a large batch of raw parts.
  • Multi-spindle grinding & polishing table: row of pneumatic rotary spindles for surface grinding and deburring.
  • Goods collection bin: finished parts are dropped straight in, with no extra handling.

Close-up details

01 · Raw part pickup (dual-part retrieval)

01 · Raw part pickup (dual-part retrieval)

The robot positions the quad-cup vacuum end effector against the inclined magazine tray and picks two parts at once. The spring-cushioned cups absorb small position errors.

02 · Rotary surface grinding & deburring

The robot guides both parts across the stationary pneumatic spindle bench, running precise motion profiles across the abrasive tooling array.
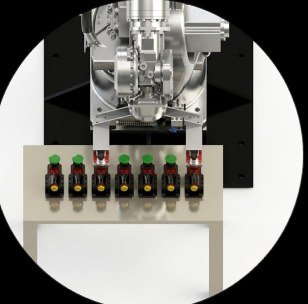
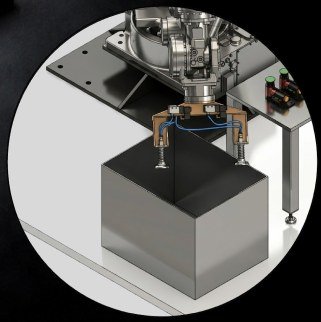
02 · Rotary surface grinding & deburring
03 · Finished part release & container drop

03 · Finished part release & container drop

Vacuum is vented through the solenoid bank, releasing the ground and deburred parts directly into the collection bin.
03 · The result

Final outcome

A cell for a GP12 / GP25 class robot with a high-density inclined infeed magazine, a multi-spindle grinding and polishing table and a collection bin. A quad-cup spring-loaded vacuum end effector picks two parts at a time, guides them across the spindles, then releases them by venting through the solenoid bank, doubling throughput per cycle.

More work

Other projects

Design
Furniture

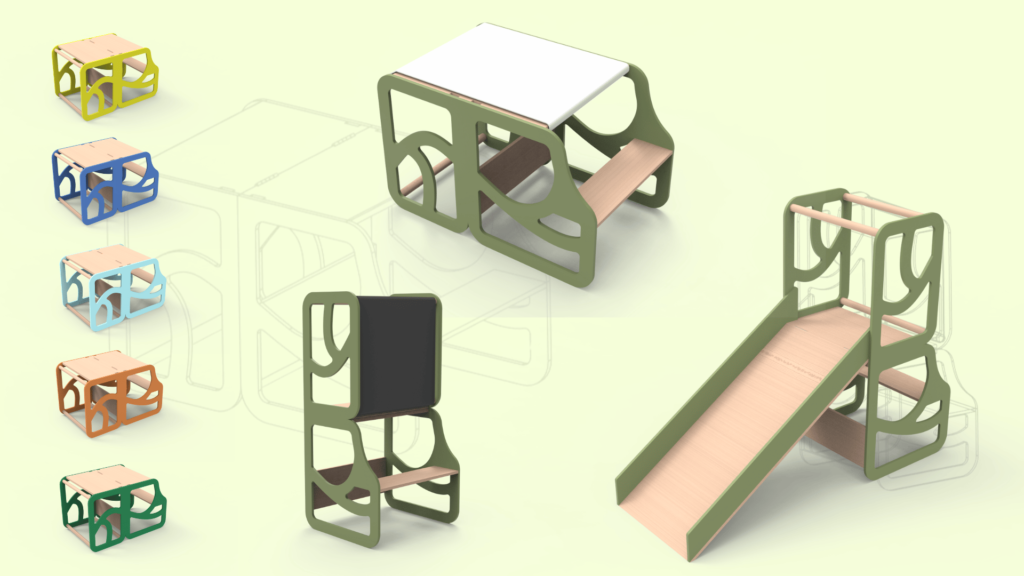
Designed for Reco, this multi-functional kids’ kitchen tower transforms into a study table, slide, drawing station, and chalkboard, encouraging creative and interactive play.

View case study →
Design
Automotive

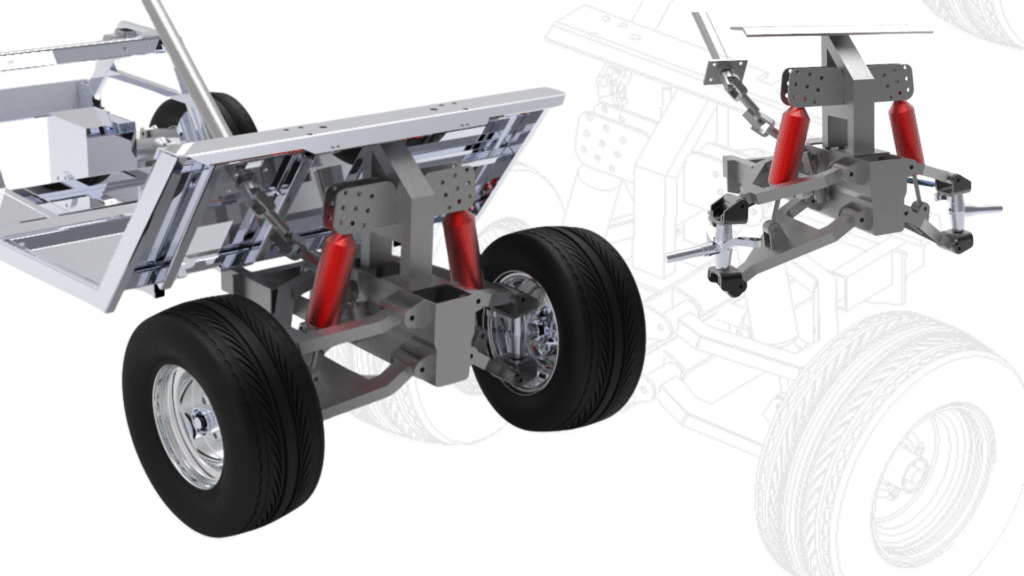
We designed a modern double wishbone front suspension and semi-trailing arm rear suspension for Auto Speed’s golf carts, replacing the old leaf springs to deliver superior ride quality and handling.

View case study →
Design
Industrial Automation

Concept study: a robotic end effector that grips an 8 kg twistlock, works its release mechanism and locks it into a corner casting, with a modular path to cover 40+ fitting types.

View case study →
Like what you see?

Let’s build your product next.

Book a free consultation and get a clear plan for your idea within one business day.